

Steel
Examples
Section titled “Examples”Scenes from the examples shelf, each run with its Steel preset: manipulation, contact-rich stacks, loop-closing linkages, cloth coupling and many worlds per GPU.
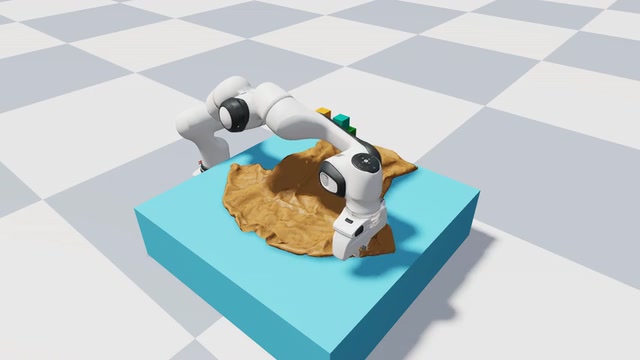
Franka shirt fold stack
A Franka folds and stacks a T-shirt with two-way cloth coupling.
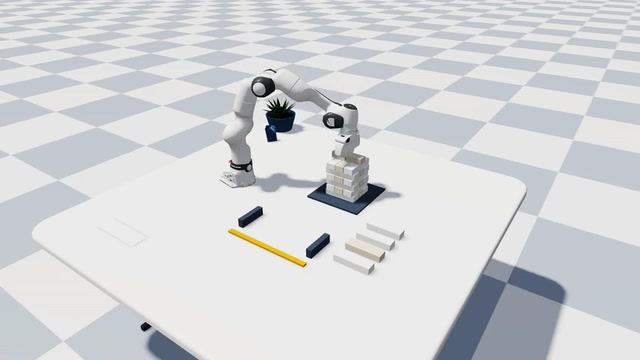
Jenga
Lift a loose block and add it to the top of the tower.
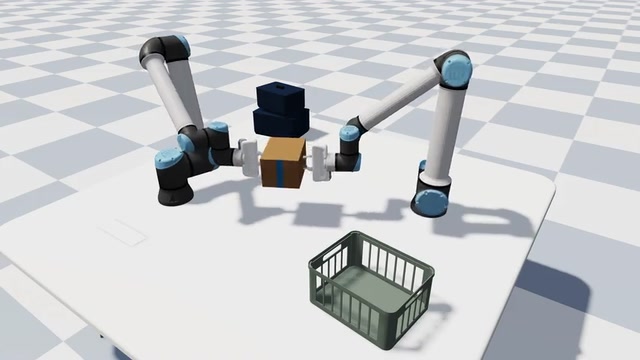
Box turn
Two arms pinch a box between their fingertips, flip it and turn it.
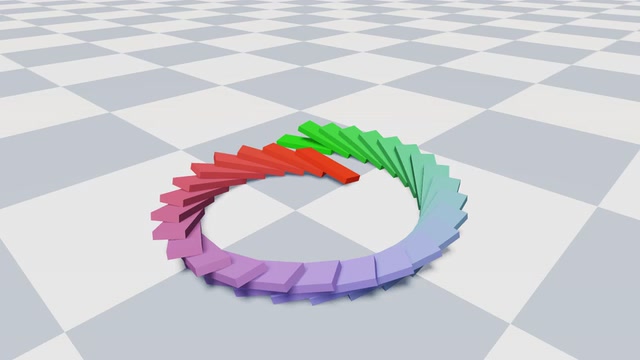
Domino spiral
Dominoes along a spiral, the first one tilted to start the chain.
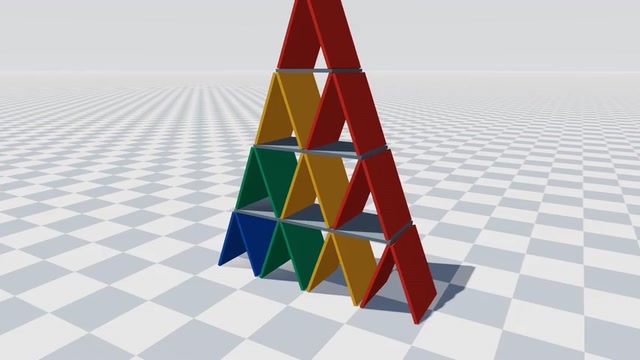
Card house
Four levels of playing cards held up by friction alone.
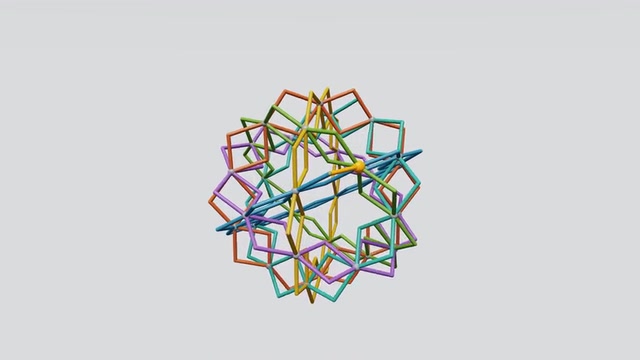
Hoberman sphere
A Hoberman sphere of 120 bars and 240 hinges opens and closes from one driven hub.
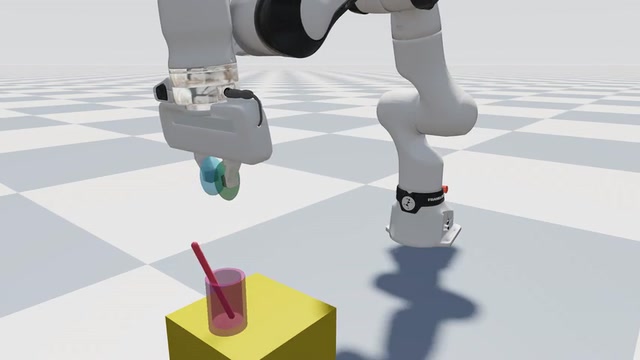
Robot panda hydro
A Franka Panda picks and places with hydroelastic contacts and inverse kinematics.
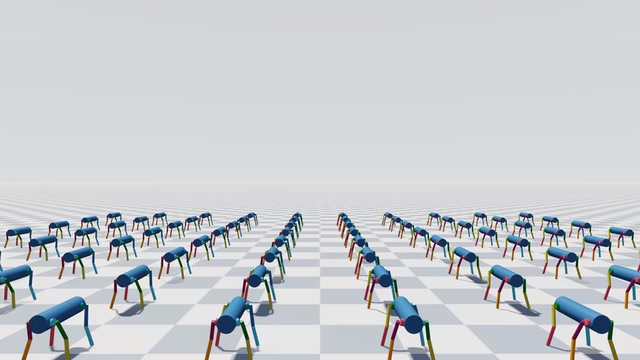
Basic urdf
A quadruped articulation loaded from URDF.
Steel lives in Newton. This site, its tutorials and the examples are in skild-ai/steel; contributions are welcome, see Contributing. Throughput benchmarks are in the launch post.
Steel docs and tutorials are licensed under Apache-2.0. Third-party notices. "Skild", "Skild AI" and the Skild logo are trademarks of Skild AI and are not licensed under Apache-2.0.